Week 3 glossary: key modelling terms
This glossary gathers the key terms used across Week 3 in one place. Keep it open as you work through the lectures and activities, and return to it whenever a term needs refreshing. Each entry notes the chapter where the idea is introduced. You don’t need to memorise these – the aim is to have them at hand.
What a model is
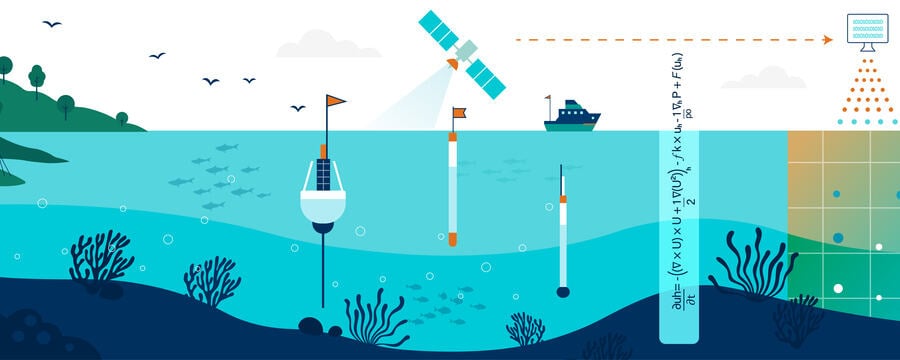
Numerical ocean model A computer program that solves the physical equations governing ocean motion on a discrete grid, simulating temperature, salinity, currents, sea level, waves, and biogeochemical variables over time.
Ocean General Circulation Model (OGCM) (Chapter 1) The baseline class of ocean model, designed to simulate the general circulation of the global or basin-scale ocean using grids from about 1° down to finer than 1/36°. Examples: NEMO, HYCOM, MITgcm, ROMS, MOM, CROCO.
Operational model (Chapter 6) A model that runs routinely (often daily) to produce real-time analyses and forecasts for practical applications. Prioritises reliability, efficiency, and timeliness over experimental features.
Hindcast, nowcast, forecast (Chapter 2) The three temporal modes of a modelling system: a hindcast reconstructs past ocean states by running a model back in time; a nowcast blends the most recent observations with the model physics to estimate the current ocean state; a forecast projects the ocean state forward, from hours to weeks ahead.
The physics and equations
Primitive equations (Chapter 1) The set of partial differential equations derived from the laws of physics (conservation of momentum, mass, heat, and salt) that form the mathematical core of every ocean model, most often solved under the Boussinesq approximation.
Boussinesq approximation (Chapter 1) A simplification of the primitive equations in which density is treated as constant except in the gravity term. Valid for most large-scale ocean motions and used in the vast majority (about 99%) of ocean models.
Hydrostatic approximation A simplification assuming that vertical pressure is balanced only by gravity (the weight of the water). Valid for large-scale ocean models; it breaks down at very high resolution where vertical accelerations matter (e.g. MITgcm can lift this assumption).
Prognostic variables (Chapter 1) Model variables that carry an explicit time derivative in the governing equations (e.g. temperature, salinity, horizontal velocities, sea surface height) and are integrated forward in time step by step.
Diagnostic variables (Chapter 1) Model variables with no time derivative, computed instantaneously from the prognostic variables through algebraic relationships (e.g. vertical velocity, pressure, density, vertical mixing coefficients).
Building the model: grids and structure
Computational grid The three-dimensional mesh of cells into which the ocean is divided. Defines where equations are solved. Can be regular (structured) or irregular (unstructured).
Arakawa grid (Chapter 3) A convention for the relative placement of scalar (temperature, salinity, sea surface height) and vector (velocity) variables within a grid cell. The Arakawa C-grid, which offsets velocity components from elevation points, is the most common choice in ocean models.
Vertical coordinates The system used to define layers in the vertical direction. Main types: z-level (fixed depth), sigma / terrain-following (layers follow the seafloor), isopycnal (layers follow density surfaces), and hybrid combinations.
Nesting (grid refinement) (Chapter 3) A technique that embeds one or more finer child grids within a coarser parent grid to concentrate resolution where it is needed (e.g. a coastal harbour), without paying the cost of high resolution everywhere.
Bathymetry The shape and depth of the ocean floor. A critical input to every ocean model – it determines water depth and controls circulation, especially in coastal areas.
Inputs and constraints
Atmospheric forcing Wind stress, heat fluxes, and precipitation from the atmosphere that drive ocean circulation. Provided to the model as boundary conditions at the sea surface.
Boundary conditions Information prescribed at the edges of the model domain (lateral open boundaries, sea surface, seafloor) to constrain the solution.
Data assimilation A technique that systematically combines model simulations with real observations (satellites, floats, moorings) to improve the accuracy of the model’s estimate of the ocean state.
Numerics: solving the equations
Discretization (Chapter 4) The process of converting continuous physical equations into a finite set of calculations performed at specific grid points and time intervals. The mathematical foundation of all numerical models.
Time stepping (Chapter 4) The process of advancing the model state from one time level to the next by solving the governing equations at each grid point.
Courant–Friedrichs–Lewy (CFL) condition (Chapters 3 & 4) The numerical stability criterion requiring that information cannot propagate across more than one grid cell per time step. It links spatial and temporal resolution: a finer grid requires a shorter time step to stay stable.
Resolution and scale
Spatial resolution (Chapter 4) The size of the grid cells. Smaller cells mean higher resolution and more detail, but greater computational cost. Typical values: 10–100 km (global), 1–10 km (regional), under 1 km (coastal).
Temporal resolution (time step, Δt) (Chapter 4) The interval between successive calculations. Must be short enough to resolve fast ocean processes, and is linked to spatial resolution: finer grids require shorter time steps (the CFL condition).
Rossby deformation radius (Chapter 4) A key length scale at which Earth’s rotation and density stratification interact. To resolve mesoscale eddies, a model’s grid spacing must be smaller than this radius – typically 10–100 km depending on latitude.
Downscaling (Chapter 6) Using the output of a coarser global model as boundary conditions for a finer regional model, allowing higher resolution in a limited area without running a global high-resolution simulation.
Unresolved processes and parameterization
Sub-grid process (Chapter 5) A physical process occurring at a scale smaller than the model’s grid spacing, such as turbulent eddies or small-scale mixing. These must be represented via parameterizations, not simulated directly.
Parameterization (Chapter 5) A mathematical approximation that represents the average effect of processes smaller than the grid size (sub-grid processes) that cannot be explicitly resolved.
Turbulence closure (Chapter 5) The set of mathematical schemes (e.g. Smagorinsky, KPP, turbulent kinetic energy, Generic Length Scale) used to approximate the collective effect of unresolved turbulent motions on the resolved flow – critical for representing mixed-layer depth and thermocline sharpness.
Turbulent mixing (Chapter 5) The chaotic, small-scale stirring of ocean water that redistributes heat, salt, and momentum. Critical for setting stratification and mixed-layer depth, but too small to resolve – always parameterised.